04 / Engineering case study
Autonomous Disaster Rescue Vehicle
A sensor-equipped robotic vehicle for remote observation and navigation experiments.
- Engineering domain
- Mobile robotics & navigation
- Project status
- Completed
Developed by Mohammed Vashir - Difficulty
- Research Level
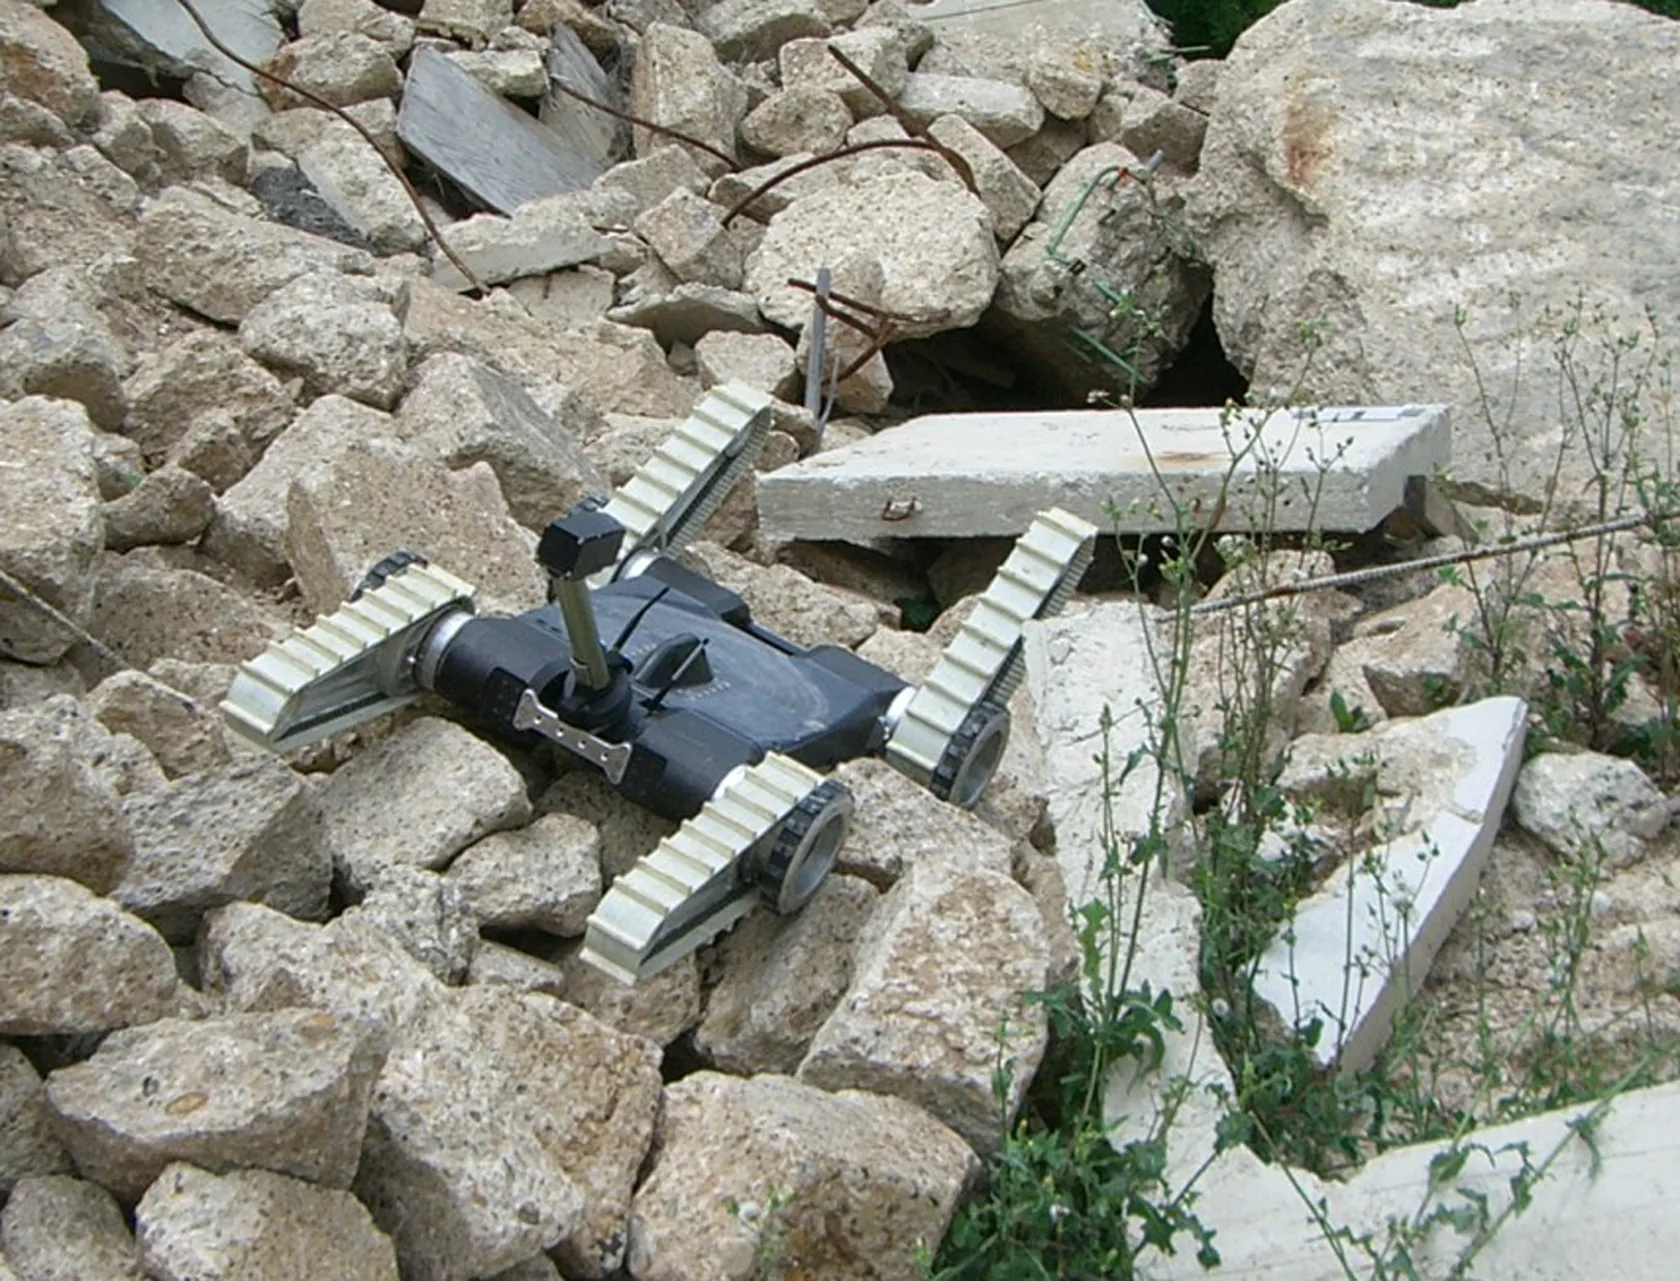 Representative imagery — not this 4TECH build.
The problem.
Remote inspection requires a mobile platform that can observe its surroundings and communicate useful information while accounting for obstacles and limits in the operating environment.
The engineering approach.
The vehicle integrates a drive system, environmental perception and an operator interface. Navigation logic and remote observation are considered together to support exploration in controlled test settings.
Engineering work includes mechanical integration, sensor interfaces, motor-control logic and communication between the vehicle and its monitoring interface. The system connects local decision-making with a practical way for an operator to review the scene.
The toolkit.
- Mobile chassis
- Embedded controller
- Obstacle sensors
- Camera
- Wireless telemetry
Engineering contribution.
Provides a mobile robotics platform for exploration, telepresence and research into assisted navigation.
Technical scope & validation
A completed research vehicle does not establish field-rescue suitability, all-terrain capability or a guarantee of safe autonomous operation.
Have a related challenge?
Start with your goal. We will work through the possibilities.