08 / Engineering case study
Advanced Robotic Arm Systems
Mechanical design and computational kinematics for coordinated robotic manipulation.
- Engineering domain
- Robotics & computational engineering
- Project status
- Completed
Developed by Mohammed Vashir - Difficulty
- Advanced
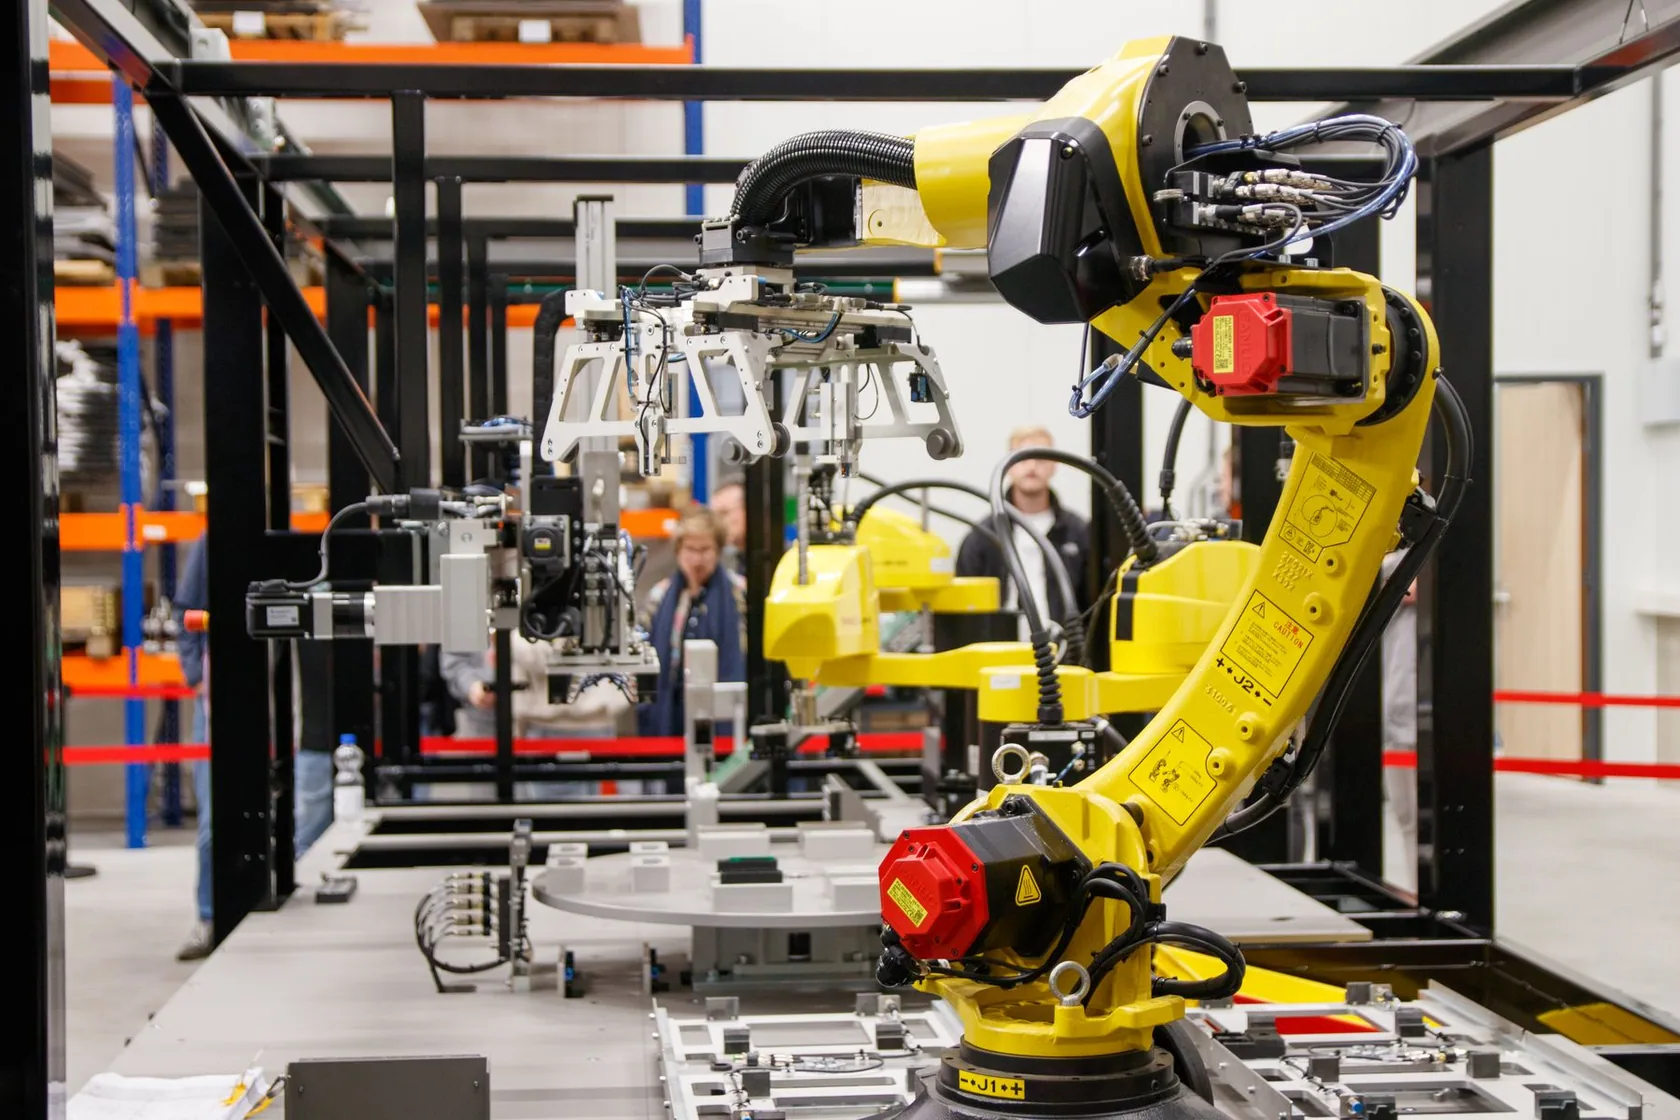 Representative imagery — not this 4TECH build.
The problem.
A robotic arm must connect its mechanical geometry to achievable end-effector positions. Joint limits, coordinate frames and the choice of kinematic solution all influence whether a motion can be executed consistently.
The engineering approach.
The project combines a five-degree-of-freedom CAD assembly with analytical and computational inverse-kinematics work. Separate modelling studies explore three- and four-degree-of-freedom formulations and neural-network approximation of joint solutions.
The engineering approach links CAD geometry, mathematical representation and software evaluation. Forward and inverse models provide a way to examine motion, compare solutions and describe the relationship between joint coordinates and the working envelope.
The toolkit.
- SOLIDWORKS
- Python
- Inverse kinematics
- Neural-network modelling
- Motion control
Engineering contribution.
Connects mechanical design with reusable kinematic models for robotic positioning and automation research.
Project documentation
What the record supports.
The available portfolio record describes a five-degree-of-freedom SOLIDWORKS assembly and separate computational kinematics studies. The models are distinct from a validated physical arm.
Mechanical assembly
Described workA five-degree-of-freedom arm assembly with articulated links, joints and gripper integration is described. The native CAD file is not in this public package.
Kinematics research
Described workAnalytical three- and four-degree-of-freedom inverse-kinematics models and neural-network approximation are described as separate studies.
Motion performance
Not verifiedNo physical build, payload test, positioning-tolerance measurement or solver benchmark is provided here.
Technical scope & validation
Degrees of freedom refer to the corresponding assembly or model. Payload ratings, positioning tolerance and comparative solver performance are not quantified in this portfolio.
What would verify performance
- Publish the CAD assembly or an export showing link dimensions, joint axes and travel limits.
- Test the analytical and learned solutions against a defined set of reachable and unreachable targets.
- If a physical arm is built, record joint motion, end-effector error and payload under stated conditions.
Have a related challenge?
Start with your goal. We will work through the possibilities.